Jui-Te "Ray" Huang
PhD student, Robotics Institute, Carnegie Mellon University

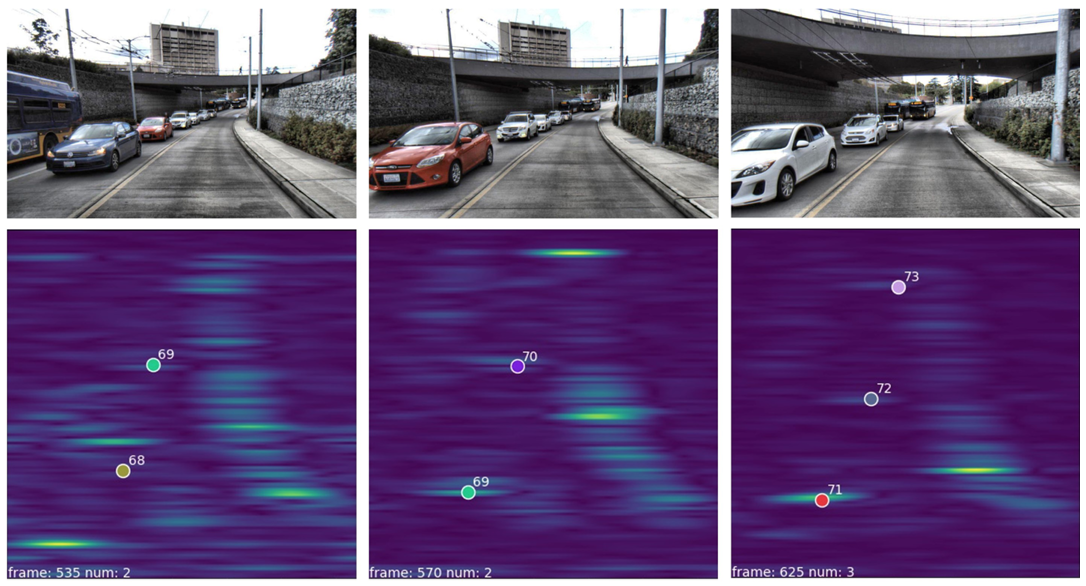
Hello! I’m Ray, a PhD student at the Robotics Institute, Carnegie Mellon University, where I’m advised by Prof. Michael Kaess in the Robot Perception Lab. I work on millimeter-wave imaging radar for robust perception in adverse environmental conditions. My recent work learns from the raw radar spectrum instead of sparse point clouds, both for radar SLAM and state estimation and for generative simulation of radar complex spectrum.
I’ve spent two summers as a research intern at Bosch Research in Pittsburgh, building a diffusion-based simulator for mmWave radar spectra. Before CMU, I received my B.S. and M.S. in Electrical and Computer Engineering from National Yang Ming Chiao Tung University, where I worked on the DARPA Subterranean Challenge.
news
| Jun 16, 2026 | Our paper “Millimeter Wave Radar: From Synthetic Aperture to Probabilistic Mapping” was accepted to IROS 2026. |
|---|---|
| Jun 01, 2026 | Won Best Student Poster at the Radar in Robotics Workshop, ICRA 2026, for UNRIO. LinkedIn post |
| Jun 01, 2026 | Our team (with Ruoyang Xu) placed 1st in the Orebro 4D-radar SLAM Challenge at the ICRA 2026 Radar in Robotics workshop! LinkedIn post |
| Jun 01, 2024 | Completed my M.S. in Robotics (MSR) at Carnegie Mellon University. |
| Mar 01, 2024 | Our paper “Multi-Radar Inertial Odometry for 3D State Estimation using mmWave Imaging Radar” was accepted to ICRA 2024. |
selected publications
- Front. Robot. AI
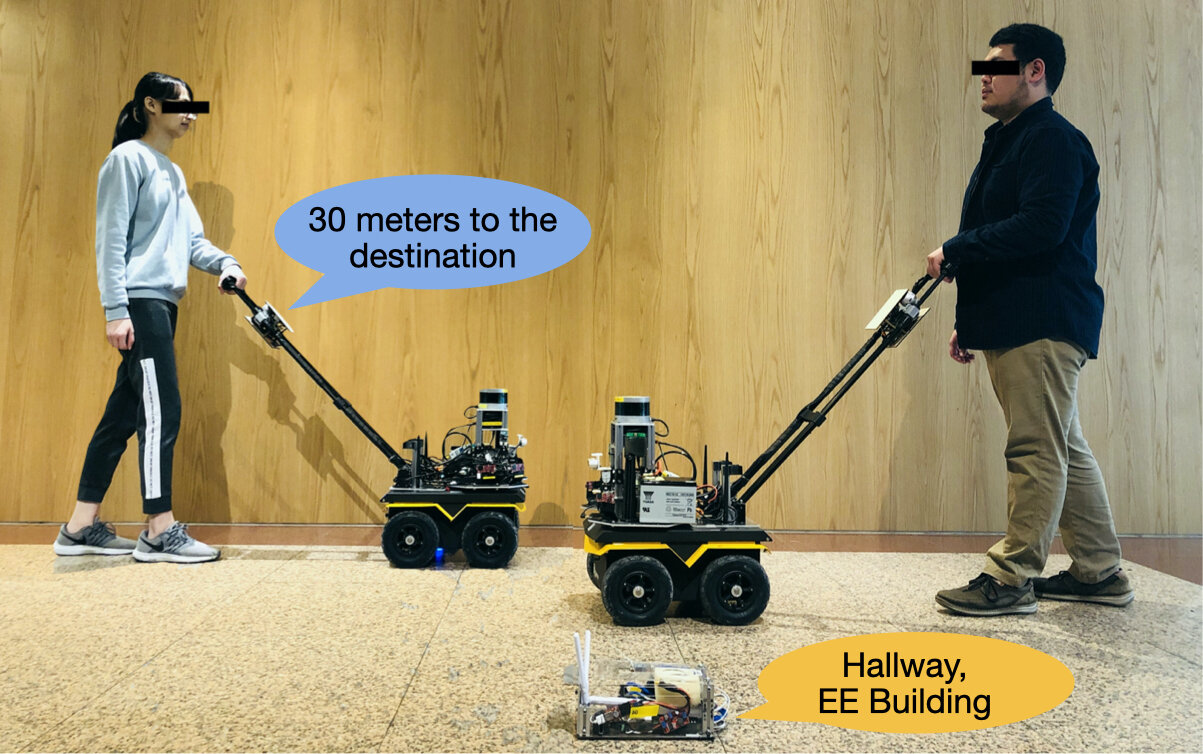
- IROS
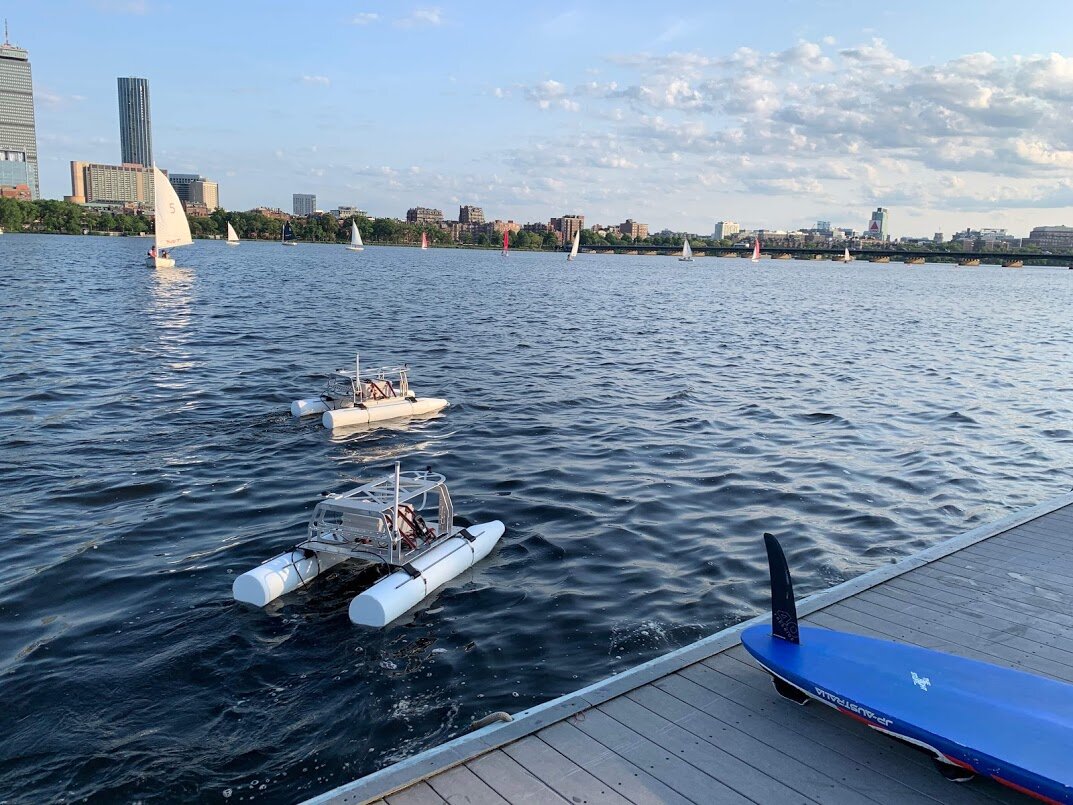 Duckiepond: An Open Education and Research Platform for a Fleet of Autonomous Maritime VehiclesIn IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS). Also presented at the Sixth Biennial Meeting of the MOOS Development and Application Working Group, Cambridge MA, 2019 , 2019