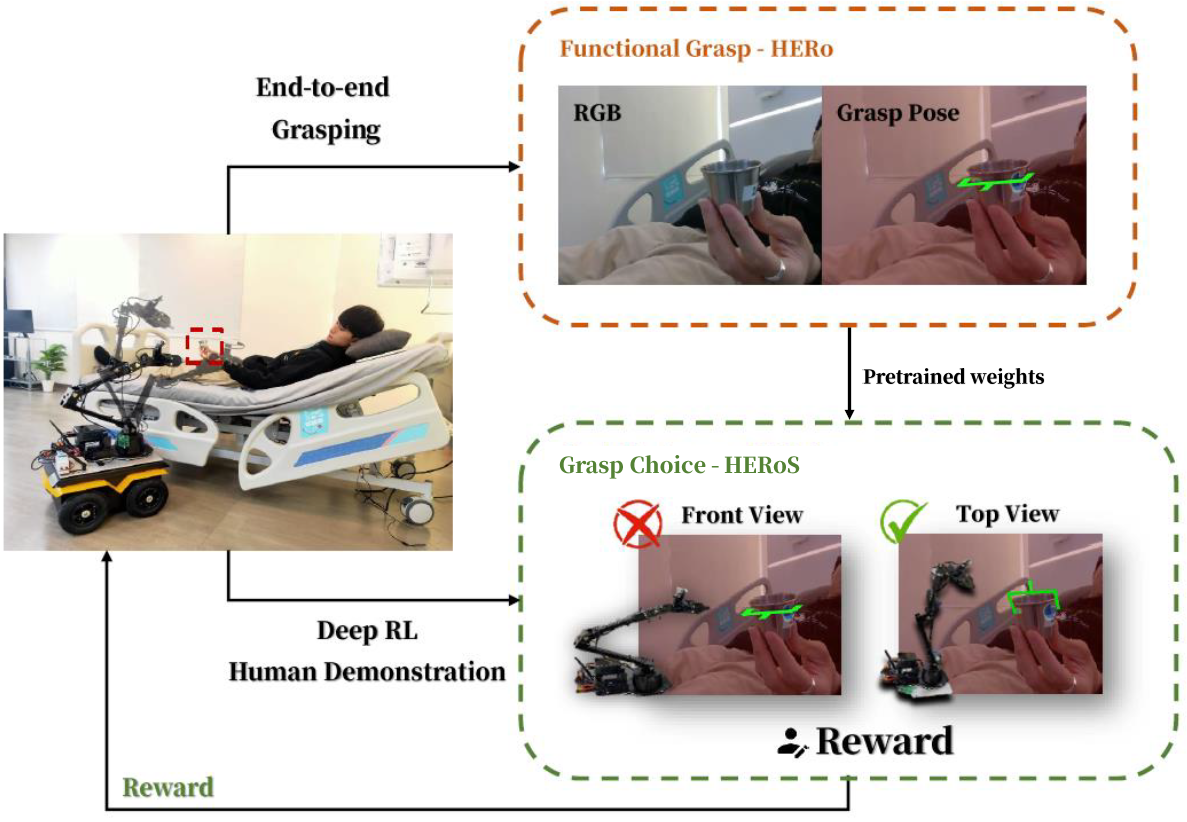
Human-to-Robot Handover via Socially-Aware End-to-End Grasping
Sample-efficient RL for non-invasive human-to-robot handover grasps
We present our socially-aware end-to-end grasping for human-to-robot handover. We first leverage existing end-to-end grasping as network backbone, and then finetune for non-invasive grasps and trajectories using sample efficient deep reinforcement learning. Comprehensive evaluations are carried out against various recent baselines using multi-stage hand and object prediction and subsequent planning.